Camera Streaming over Heterogeneous Robot Networks
Software Engineering Intern, ROBROS · Dec 2025 – Mar 2026
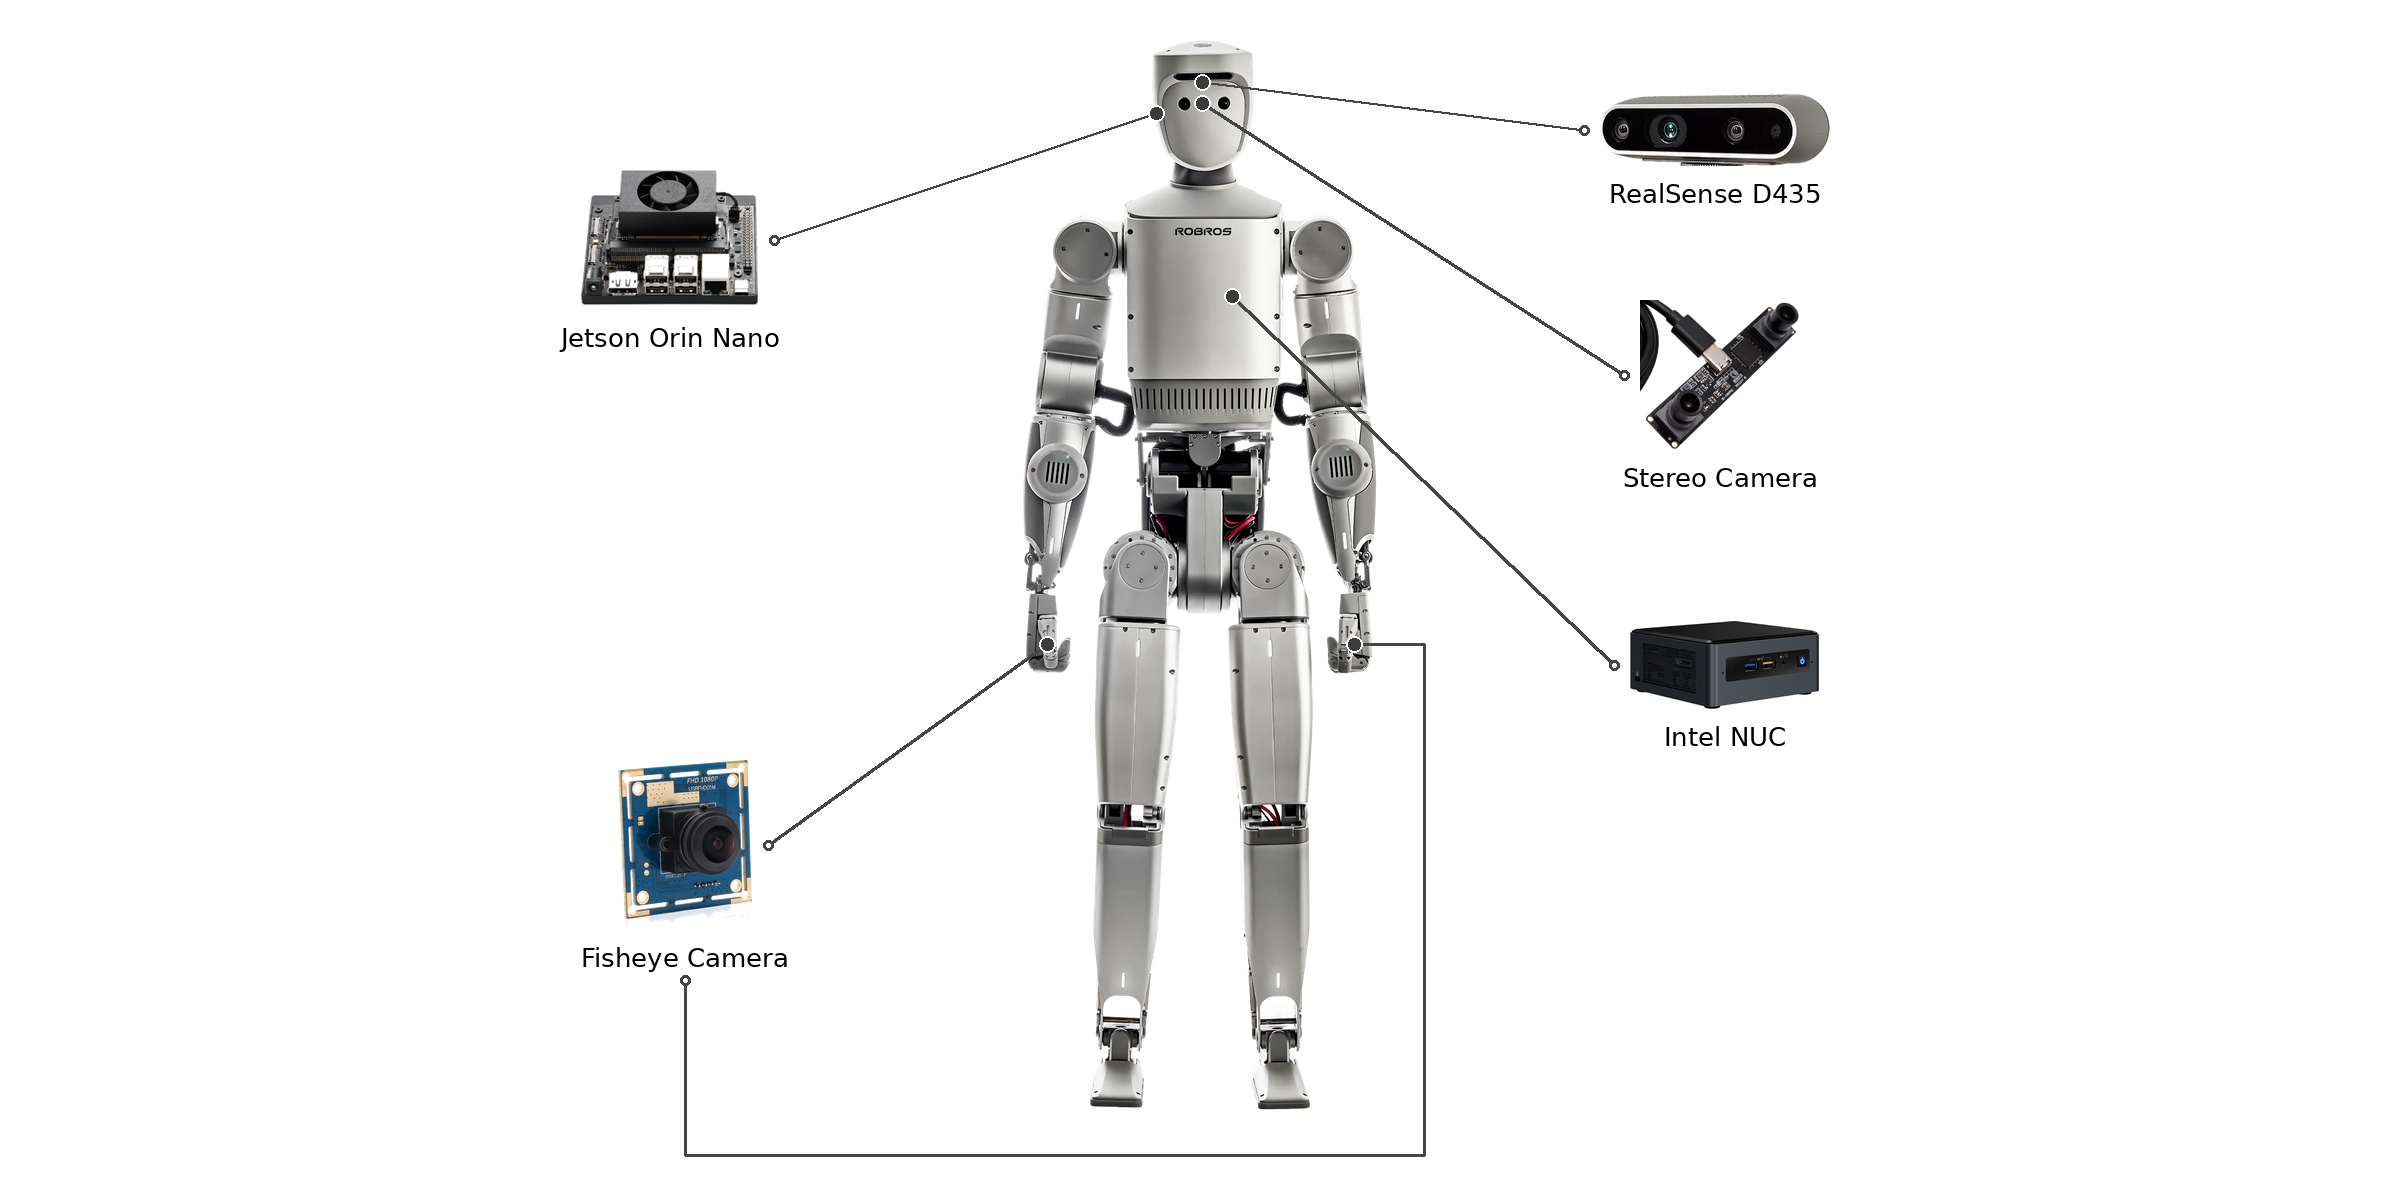
Made multi-camera video stream reliably from a robot's onboard computer to client PCs across a combined wired + WiFi network, as a camera streaming setup built with SLAM in mind, and automated setup, deployment and recovery.
Goal: a camera streaming environment that SLAM could run on.
Robot middleware (CycloneDDS) communication did not work across LAN + WiFi; the starting send/receive code failed.
The bridge between networks dropped packets, WiFi/AP switching broke routing, and UDP buffers overflowed under image load.
Image transport — designed the image message format and built Python/C++ send/receive for depth and stereo cameras.
Cross-network bridge — fixed packet drops with IP forwarding, NAT and route control.
Network automation — auto-reset routes on WiFi/AP switch and auto-discover the bridge, so no manual config.
Stability — raised UDP buffers, tuned resolution/FPS for latency vs quality, per-camera multithreading.
Deployment — systemd auto-start/restart, Cython packaging, docs and handover.
Streaming working end to end (LAN, WiFi and AP mode) and reproduced on a new device.
End-to-end Python implementation, with parts in C++.